Abstract
Field-Oriented Control (FOC) enables Permanent Magnet Synchronous Motor (PMSM) drives to achieve a DC-like, decoupled control structure by independently regulating torque and flux producing current components in a synchronously rotating reference frame aligned with the rotor magnetic field. Unlike induction machines, where rotor flux must be established through stator excitation and slip frequency tracking, PMSMs inherently provide excitation through permanent magnets. Consequently, the d-axis current influences the resultant air gap flux linkage and, depending on the machine topology, may also contribute to torque optimization. In surface mounted PMSMs (SPMSMs), the d-axis current is typically regulated near zero under nominal operating conditions (idref ≈ 0), whereas in interior PMSMs (IPMSMs), a nonzero negative d-axis current is often employed to exploit rotor saliency for Maximum Torque Per Ampere (MTPA) operation and flux weakening. The measured three phase stator currents are transformed into the rotating d–q reference frame using Clarke and Park transformations, where the q-axis current primarily governs electromagnetic torque production. This representation enables fast dynamic response through conventional PI current regulators, optionally enhanced with cross-coupling compensation. Accurate electrical angle information, θe, is obtained from a position sensor (e.g., encoder or resolver) or a sensorless estimation algorithm to maintain proper reference frame alignment. The resulting voltage commands are transformed back to the stationary reference frame via the inverse Park transformation and applied to the inverter using Space Vector Pulse Width Modulation (SVM), enabling efficient synthesis of the commanded stator voltages. The resulting control architecture provides high torque bandwidth, low torque ripple, high efficiency, and reliable operation over a wide speed range, including MTPA and flux-weakening regions in high-performance PMSM drive systems.
1 Introduction
The evolution of industrial electric drives has been fundamentally reshaped by advances in power electronics, digital signal processors, and high-performance microcontrollers, enabling the practical implementation of sophisticated vector control strategies. Among these, Field-Oriented Control (FOC) has become the dominant control technique for high-performance Permanent Magnet Synchronous Motor (PMSM) drives due to its ability to provide fast and accurate torque control over a wide operating range [1], [2]. By employing space vector concepts together with Clarke and Park coordinate transformations, FOC transforms the three phase stator variables into a synchronously rotating reference frame aligned with the rotor magnetic field. This transformation enables independent regulation of the d-axis and q-axis current components, resulting in a control structure that closely resembles the decoupled torque control characteristics of a conventional DC motor [1], [3].
The widespread adoption of PMSM drives in industrial automation, robotics, electric vehicles, and high-performance motion control systems is largely attributed to their high efficiency, high torque density, compact construction, and elimination of mechanical commutation [4]. However, realizing the full performance potential of PMSMs requires control methods capable of handling the inherent nonlinearities and dynamic interactions present in AC machines. Conventional scalar control techniques, such as constant voltage to frequency (V/f) control, rely primarily on steady-state assumptions and therefore provide limited dynamic performance during rapid speed or load variations. Under such conditions, these methods may exhibit slow transient response, increased current oscillations, reduced efficiency, and degraded torque regulation [1].
In contrast, FOC regulates the stator current components within a synchronously rotating d–q reference frame locked to the rotor electrical position, θe. In PMSM drives, this orientation is achieved using rotor position information obtained either from a position sensor (e.g., encoder or resolver) or from a sensorless estimation algorithm. Unlike induction-machine implementations of FOC, PMSM drives do not require slip-frequency estimation to maintain field orientation because the rotating reference frame is directly aligned with the rotor permanent-magnet flux [1]-[6].
Within this framework, the q-axis current serves as the primary torque-producing component, while the d-axis current influences the resultant air gap flux linkage and, in interior PMSMs (IPMSMs), contributes to reluctance torque production arising from rotor saliency. Consequently, the d-axis current reference is commonly maintained near zero in surface mounted PMSMs (SPMSMs), whereas a negative d-axis current is frequently employed in IPMSMs to achieve Maximum Torque Per Ampere (MTPA) operation and to extend the speed range through flux weakening. This capability allows the controller to exploit the electromagnetic characteristics of different PMSM topologies while maintaining efficient torque production across a broad operating range [2], [4], [6].
At elevated operating speeds, cross coupling effects between the d-axis and q-axis current dynamics, together with increasing back electromotive force (back-EMF) influence, can significantly affect current regulation performance. Therefore, practical high-performance PMSM drives commonly incorporate decoupling and feedforward compensation terms within the current control loops to improve dynamic response and reduce axis interaction [5], [6]. Combined with high bandwidth PI current regulators and advanced modulation techniques such as Space Vector Pulse Width Modulation (SVM), FOC enables precise current regulation, low torque ripple, high efficiency, and robust operation over a wide range of speeds and load conditions [1]- [6].
2 Functional Analysis of the FOC Block Diagram
The control process (see Fig. 1) begins with the measurement of the motor phase currents. Since the effectiveness of field-oriented control depends on accurate current decomposition, the quality of current sensing and signal conditioning is critical, directly influencing current-regulation accuracy, torque ripple, and overall closed-loop stability [1], [2], [5], [6]. The measured three-phase currents are first processed by the Clarke Transformation block to obtain the stationary reference frame components (iα and iβ). These components, together with the instantaneous rotor electrical angle θe, are subsequently transformed into the synchronously rotating d–q reference frame through the Park Transformation. By projecting the sinusoidal stator currents onto a reference frame rotating synchronously with the rotor magnetic field, the fundamental time varying behavior is removed. The resulting d-axis and q-axis current components, id and iq, become quasi DC quantities under steady state conditions, enabling conventional PI regulators to achieve accurate current regulation with zero steady-state error while avoiding the complexity of directly controlling sinusoidal variables in the stationary frame [1]–[3].
Within the d–q reference frame, the d-axis and q-axis current dynamics can be approximately decoupled through appropriate feedforward compensation [5], [6]. The overall control structure typically follows a cascaded architecture in which an outer speed-control loop generates a torque reference (Tref), or equivalently a q-axis current reference. Between the speed controller and the inner current-control loops, a PMSM current reference generation block - typically incorporating Maximum Torque Per Ampere (MTPA) and flux-weakening algorithms - computes the current commands idref and iqref. In PMSM drives, the dominant excitation is provided by the permanent magnets, while the d-axis current influences the resultant air gap flux linkage and, in interior PMSMs (IPMSMs), contributes to reluctance torque production due to rotor saliency. Consequently, idref is commonly maintained near zero in surface mounted PMSMs (SPMSMs), whereas a negative d-axis current is frequently employed in IPMSMs to maximize torque utilization and extend the operating speed range through flux weakening. This hierarchical control structure enables independent tuning of the speed and current loops, resulting in robust stability, fast transient response, and efficient torque production over a wide operating range [1]–[6].
On the output side of the control system, the voltage commands generated by the d-axis and q-axis PI current regulators are combined with decoupling/feedforward compensation terms before being applied to the inverse coordinate transformation stage. These compensation terms generate additional voltage commands based on the measured current components, electrical angular velocity, machine inductances, and permanent magnet flux linkage, thereby counteracting cross coupling effects and reducing the influence of back electromotive-force (back-EMF), particularly at elevated operating speeds. As a result, the current-control loops exhibit improved linearity, reduced axis interaction, and enhanced dynamic performance. The compensated voltage references vd*ref and vq*ref are then transformed back to the stationary α-β reference frame through the Inverse Park Transformation. These stationary frame voltage references are subsequently processed by the Space Vector Pulse Width Modulation (SVM) stage, which converts the continuous control commands into inverter switching signals. Acting as the interface between the control algorithm and the voltage source inverter, SVPWM provides efficient DC-bus utilization, reduced harmonic distortion, and improved voltage synthesis capability compared with conventional modulation techniques [1]–[4].
A critical requirement for successful field-oriented operation is the accurate determination of the rotor electrical angle θe, which is required by both the Park and Inverse Park transformations. Unlike induction machine implementations of FOC, PMSM drives do not require slip frequency estimation because the rotating reference frame is directly aligned with the rotor permanent magnet field. In sensored systems, θe is obtained from an encoder or resolver and converted to electrical angle using the machine pole-pair count. In sensorless implementations, θe is estimated using model-based observer techniques such as back-EMF observers, sliding-mode observers, or extended Kalman filters, which reconstruct rotor position and speed from measured stator voltages, currents, and machine parameters. Nevertheless, low speed and near zero speed operation remain challenging because the back-EMF magnitude decreases significantly while parameter sensitivity increases. Consequently, robust sensorless control in these operating regions often requires advanced observer structures and/or signal injection techniques to maintain reliable field orientation and accurate torque control [1]-[6].
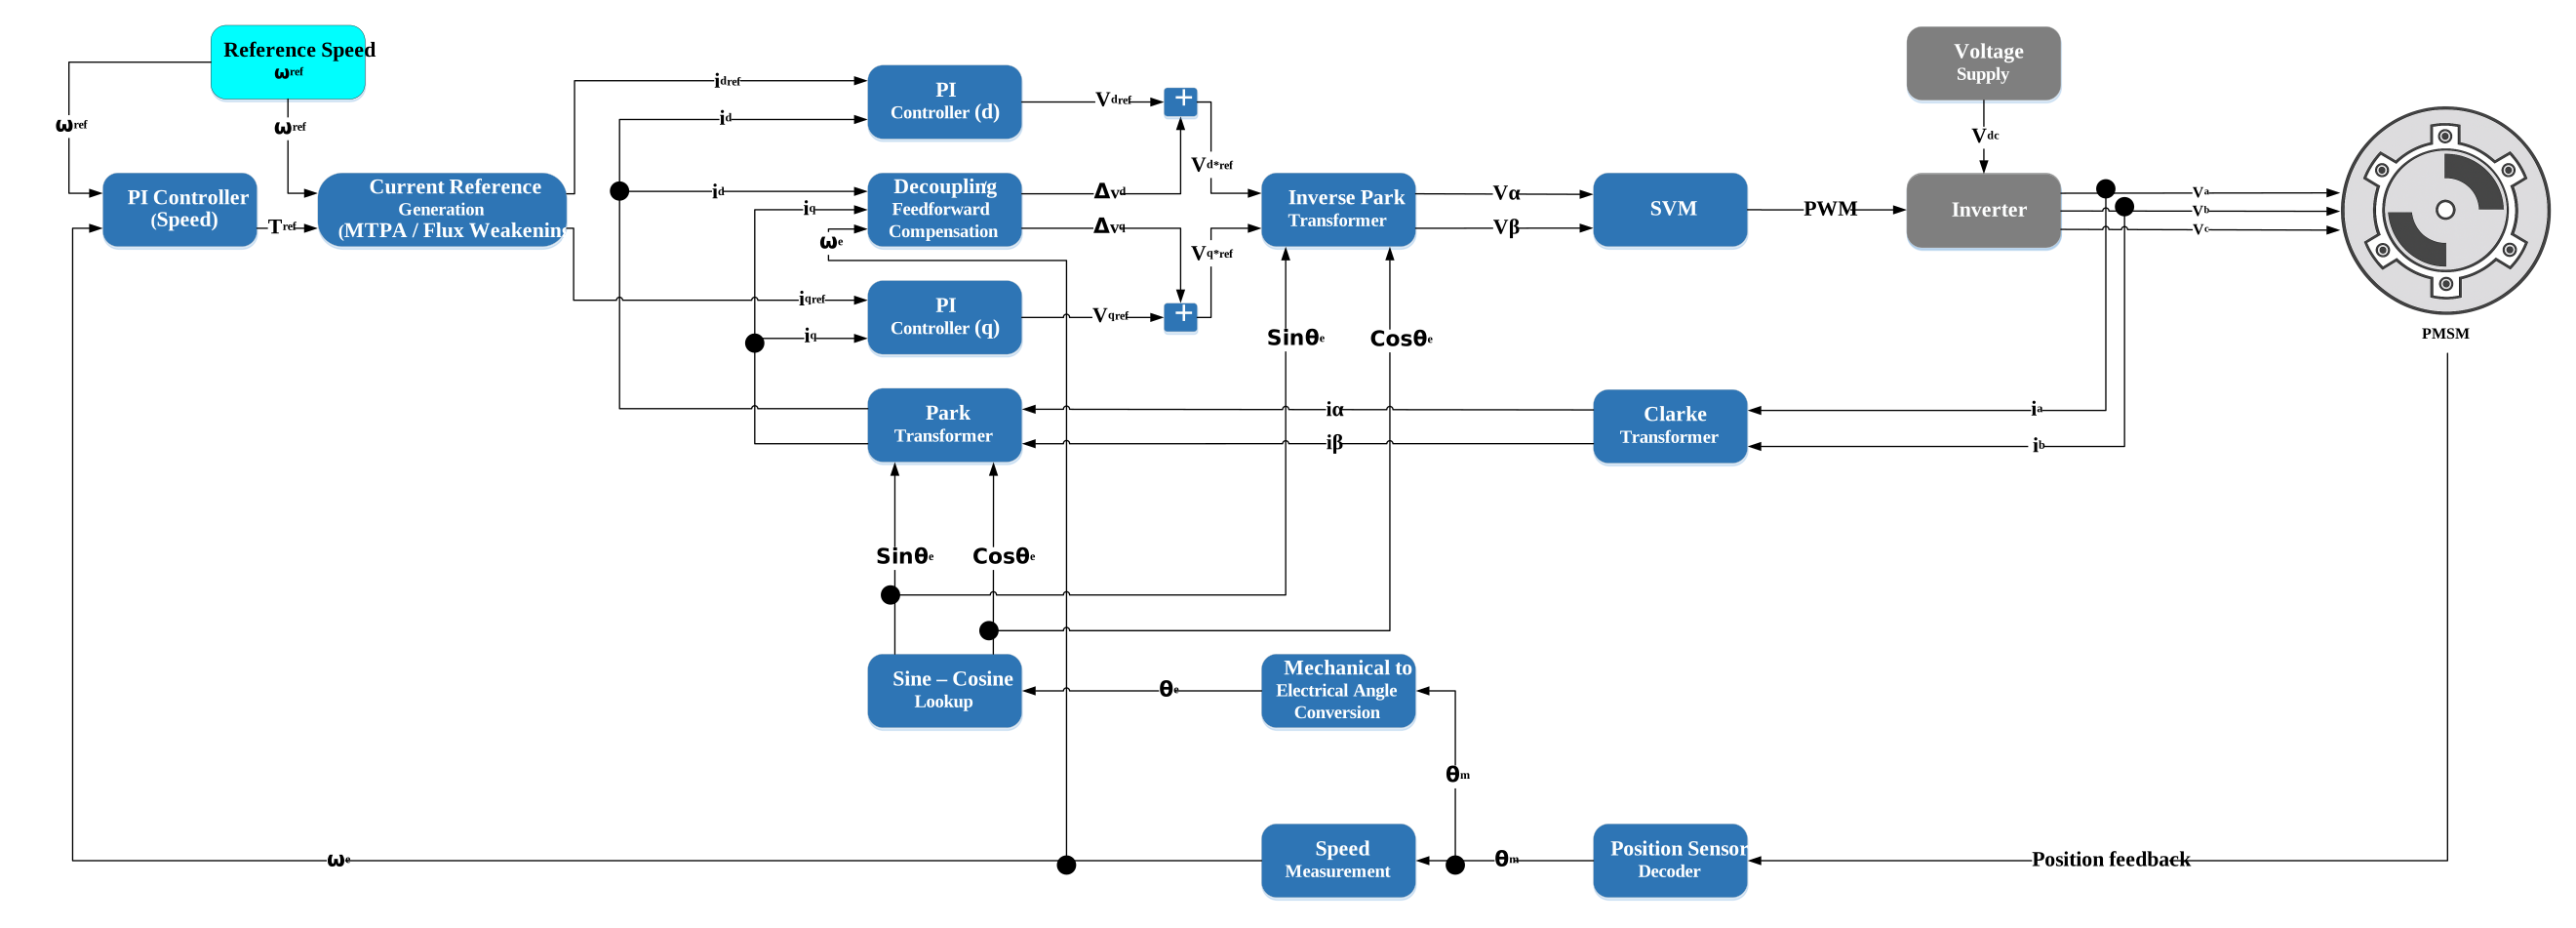
Fig. 1. Field-Oriented Control (FOC) architecture for a Permanent Magnet Synchronous Motor (PMSM). The control scheme utilizes a cascaded structure where the outer speed loop generates a torque reference (Tref). This is processed by the Current Reference Generation block, incorporating MTPA (Maximum Torque Per Ampere) or Flux Weakening strategies to define the optimal d-q current set points (idref, iqref). Stator currents are measured and mapped to the rotating frame via Clarke and Park transformations. To improve dynamic performance, a Decoupling/Feedforward Compensation block offsets the cross coupling effects and back-EMF, which are added to the outputs of the PI Current Controllers to form the final voltage commands (Vd∗ref, ,Vq∗ref). These are subsequently converted to the stationary α-β frame and synthesized by the SVM (Space Vector Modulation) block to drive the inverter. The system synchronization is maintained by a Position Sensor Decoder and Mechanical to Electrical conversion logic, providing the precise rotor flux angle (θe) required for frame transformations.
3 References
[1] B. K. Bose, Power Electronics and Motor Drives: Advances and Trends. Amsterdam, The Netherlands: Elsevier, 2010.
[2] M. M. Elkholy, M. M. Algendy, and E. A. El-Hay, “Modern Control Techniques and Operational Challenges in Permanent Magnet Synchronous Motors: A Comprehensive Review,” Automation, vol. 6, no. 4, p. 49, 2025, doi: 10.3390/automation6040049.
[3] D. W. Novotny and T. A. Lipo, Vector Control and Dynamics of AC Drives, vol. 41. Oxford, UK: Oxford University Press, 1996.
[4] A. Benevieri, L. Carbone, S. Cosso, K. Kumar, M. Marchesoni, M. Passalacqua, and L. Vaccaro, “Surface Permanent Magnet Synchronous Motors’ Passive Sensorless Control: A Review,” Energies, vol. 15, no. 20, p. 7747, 2022, doi: 10.3390/en15207747.
[5] S. K. Sul, Control of Electric Machine Drive Systems. Hoboken, NJ, USA: John Wiley & Sons, 2011.
[6] R. Krishnan, Permanent Magnet Synchronous and Brushless DC Motor Drives. Boca Raton, FL, USA: CRC Press, 2017.